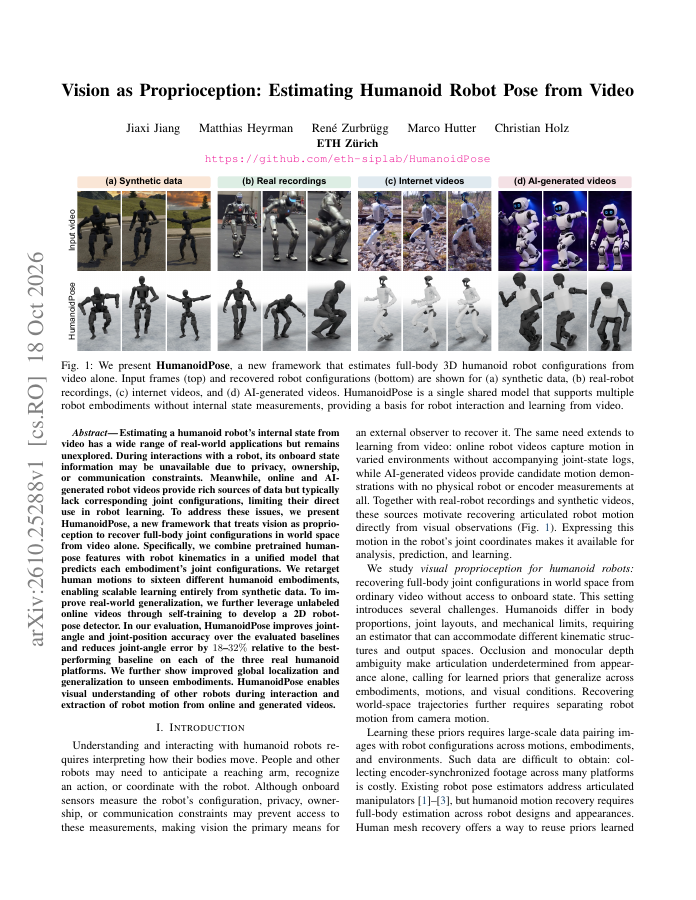
Vision as Proprioception: Estimating Humanoid Robot Pose from Video
18 Oct 2026
Estimating a humanoid robot's internal state from video has a wide range of real-world applications but remains unexplored. During interactions with a robot, its onboard state information may be unavailable due to privacy, ownership, or communication constraints.