Long-WAM: Scaling the Context of World-Action Models
7 Oct 2026
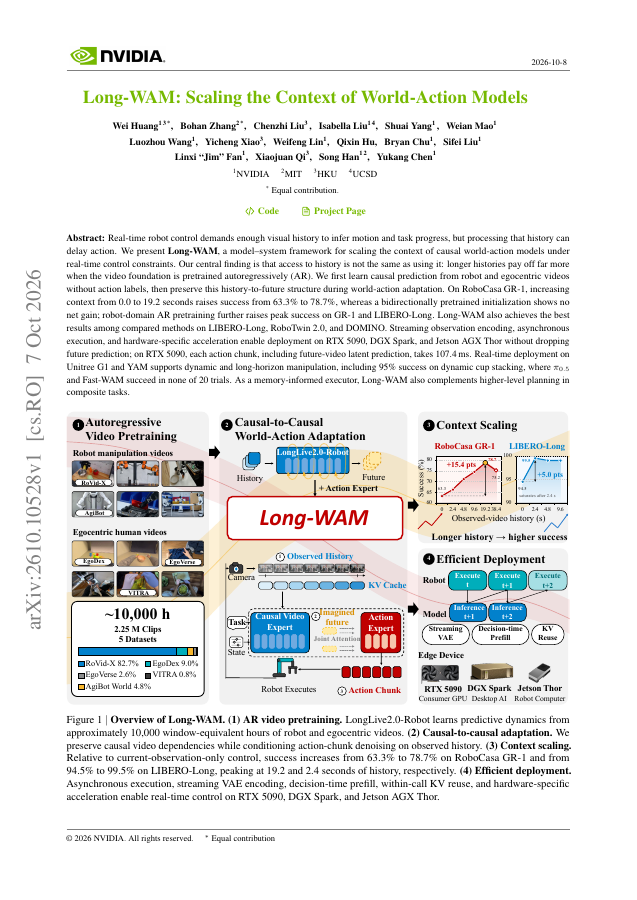
Real-time robot control demands enough visual history to infer motion and task progress, but processing that history can delay action. We present Long-WAM, a model-system framework for scaling the context of causal world-action models under real-time control constraints.
2.8k0.1/h