19 Oct 2026
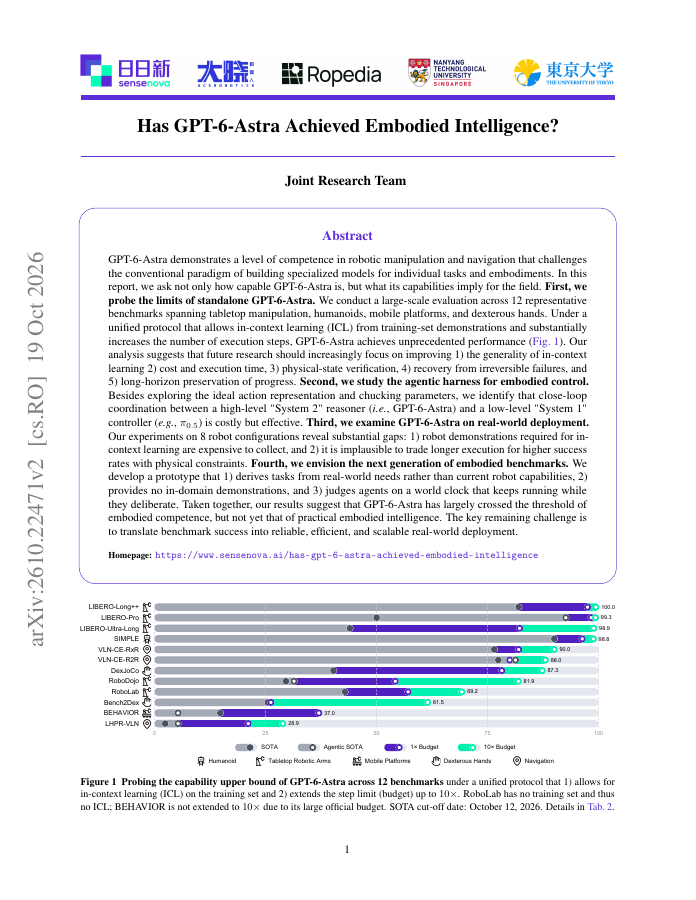
GPT-6-Astra demonstrates a level of competence in robotic manipulation and navigation that challenges the conventional paradigm of building specialized models for individual tasks and embodiments.
Trending research and the full catalog - each paper linked to the benchmarks, methods, and models it introduces.
Filtering here covers the 2,000 most recent papers, as much as one page can hold in memory. See the full index of 22,656 papers.
19 Oct 2026
GPT-6-Astra demonstrates a level of competence in robotic manipulation and navigation that challenges the conventional paradigm of building specialized models for individual tasks and embodiments.
8 Oct 2026
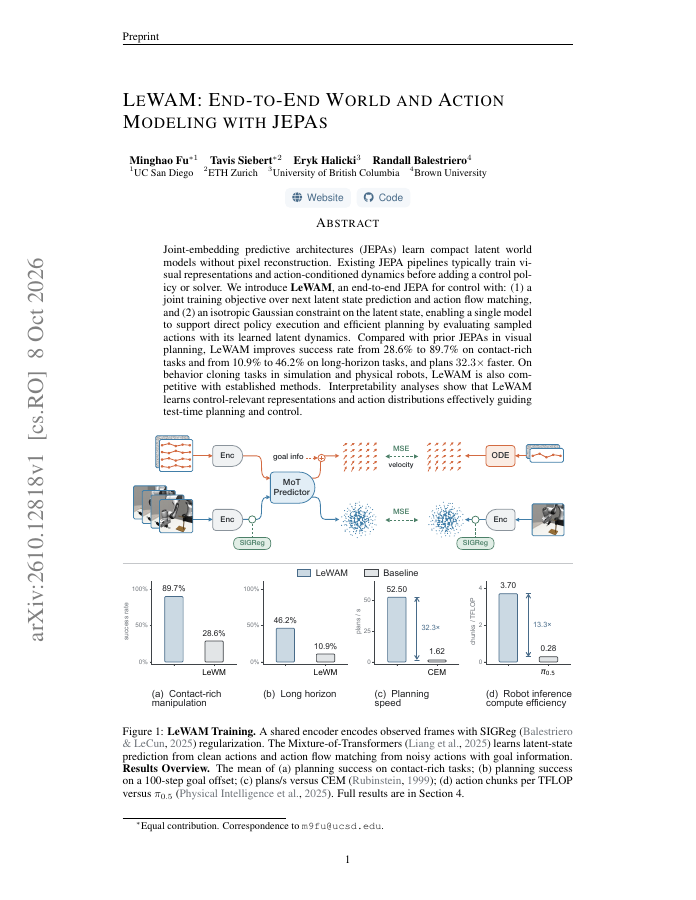
Joint-embedding predictive architectures (JEPAs) learn compact latent world models without pixel reconstruction. Existing JEPA pipelines typically train visual representations and action-conditioned dynamics before adding a control policy or solver.
5 Oct 2026
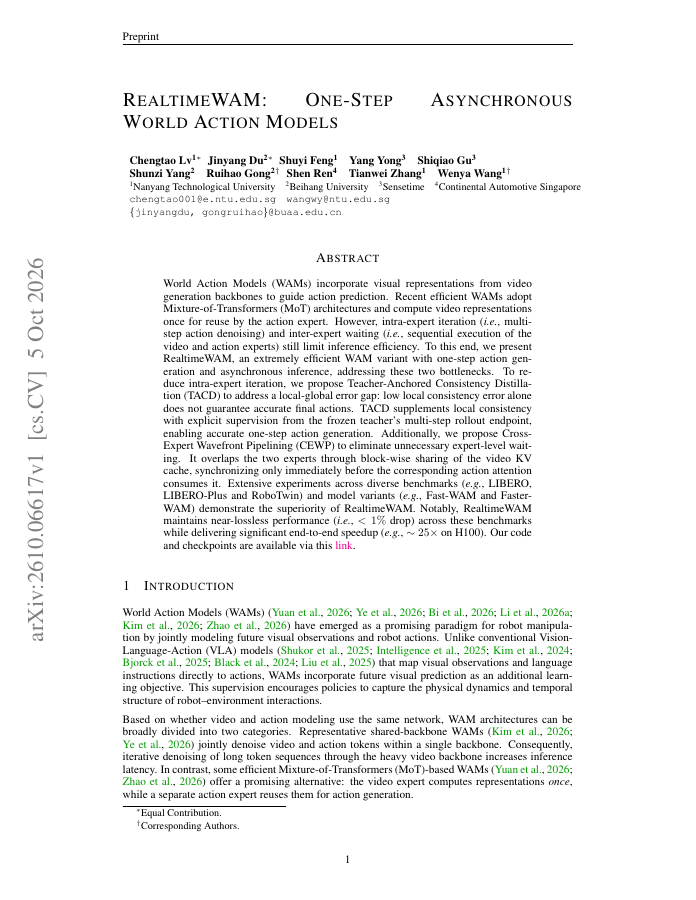
World Action Models (WAMs) incorporate visual representations from video generation backbones to guide action prediction. Recent efficient WAMs adopt Mixture-of-Transformers (MoT) architectures and compute video representations once for reuse by the action expert.
7 Oct 2026
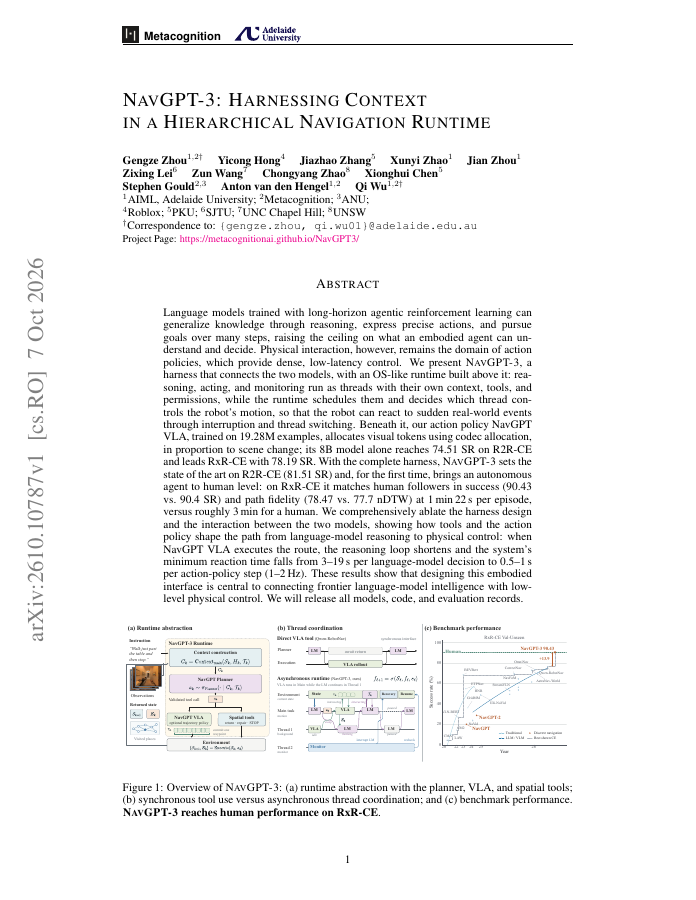
Language models trained with long-horizon agentic reinforcement learning can generalize knowledge through reasoning, express precise actions, and pursue goals over many steps, raising the ceiling on what an embodied agent can understand and decide.
7 Oct 2026
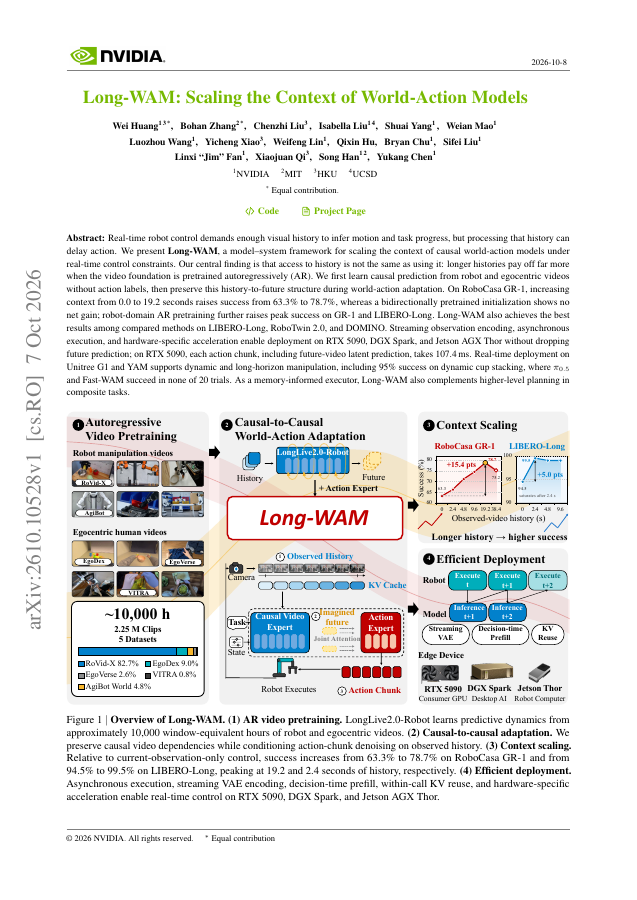
Real-time robot control demands enough visual history to infer motion and task progress, but processing that history can delay action. We present Long-WAM, a model-system framework for scaling the context of causal world-action models under real-time control constraints.
16 Oct 2026
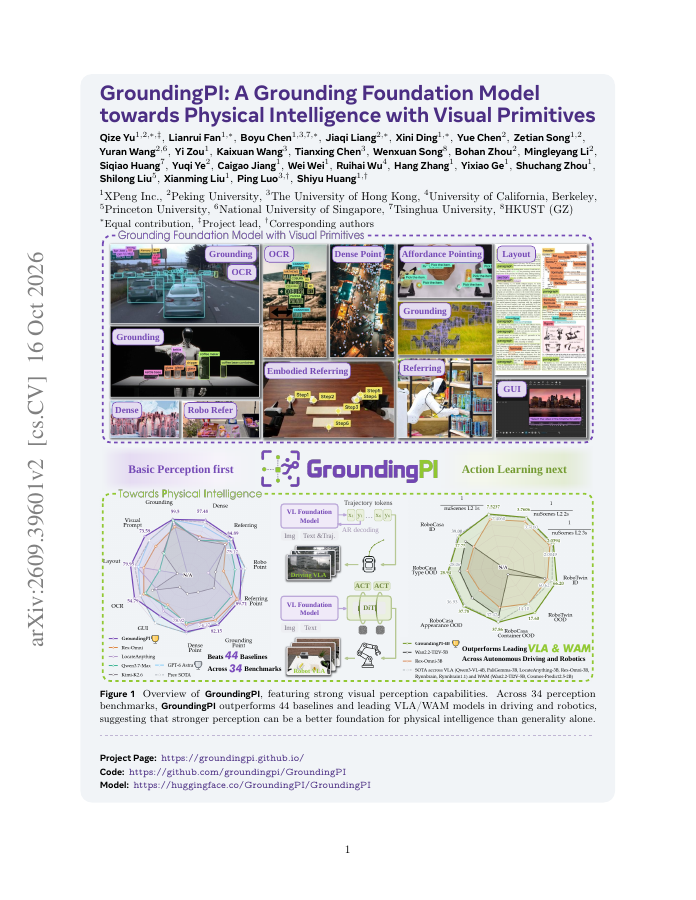
Precise grounding matters. It specifies which object is the target and where that object is, even in clutter and for tiny objects, and it has to be fast enough for closed-loop control.
5 Oct 2026
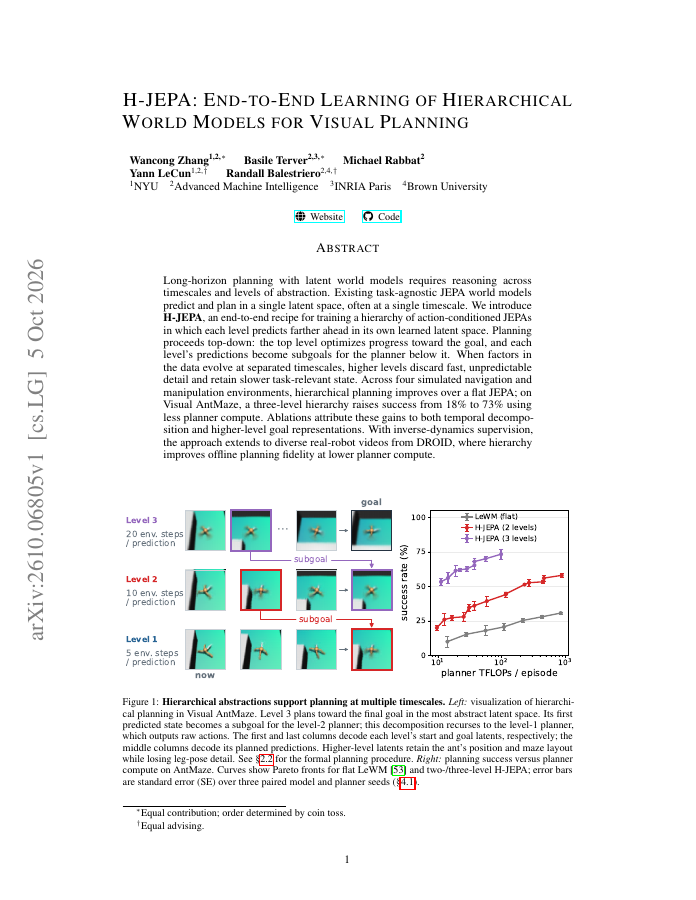
Long-horizon planning with latent world models requires reasoning across timescales and levels of abstraction. Existing task-agnostic JEPA world models predict and plan at a single timescale or with multiple horizons in one shared latent space.
18 Oct 2026
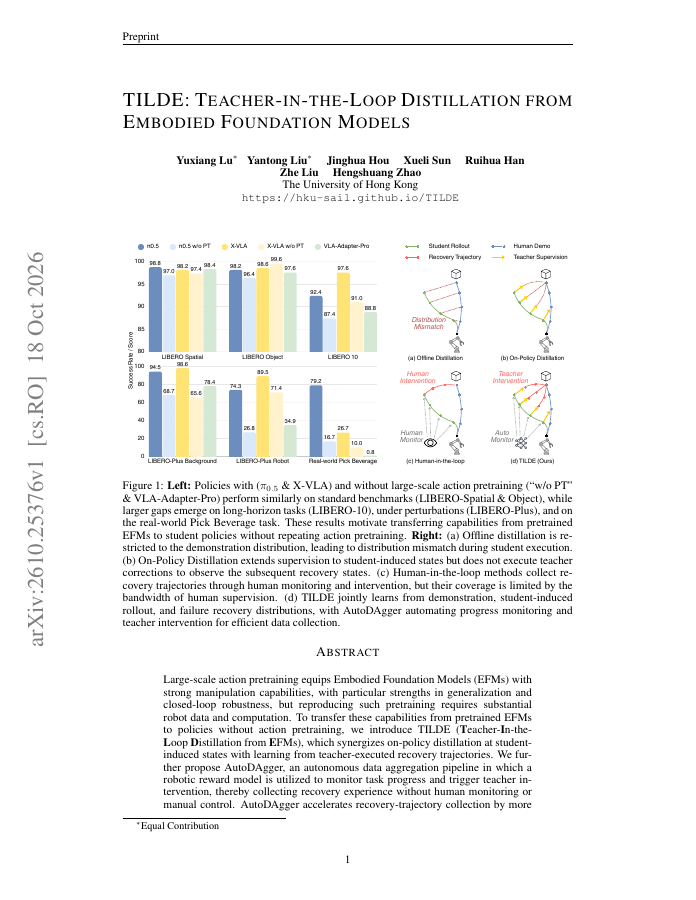
Large-scale action pretraining equips Embodied Foundation Models (EFMs) with strong manipulation capabilities, with particular strengths in generalization and closed-loop robustness, but reproducing such pretraining requires substantial robot data and computation.
18 Oct 2026
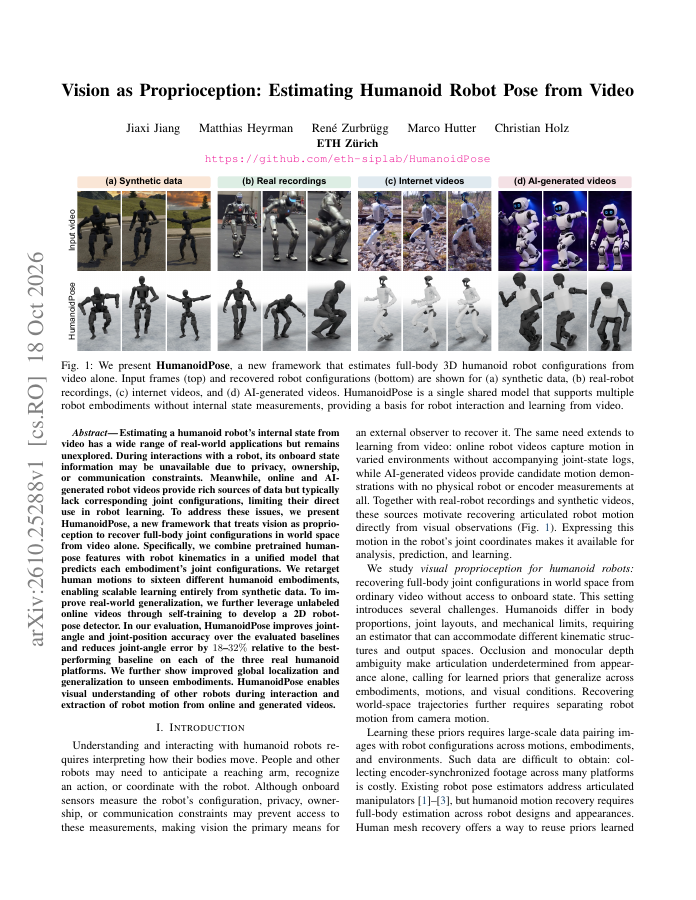
Estimating a humanoid robot's internal state from video has a wide range of real-world applications but remains unexplored. During interactions with a robot, its onboard state information may be unavailable due to privacy, ownership, or communication constraints.
18 Oct 2026
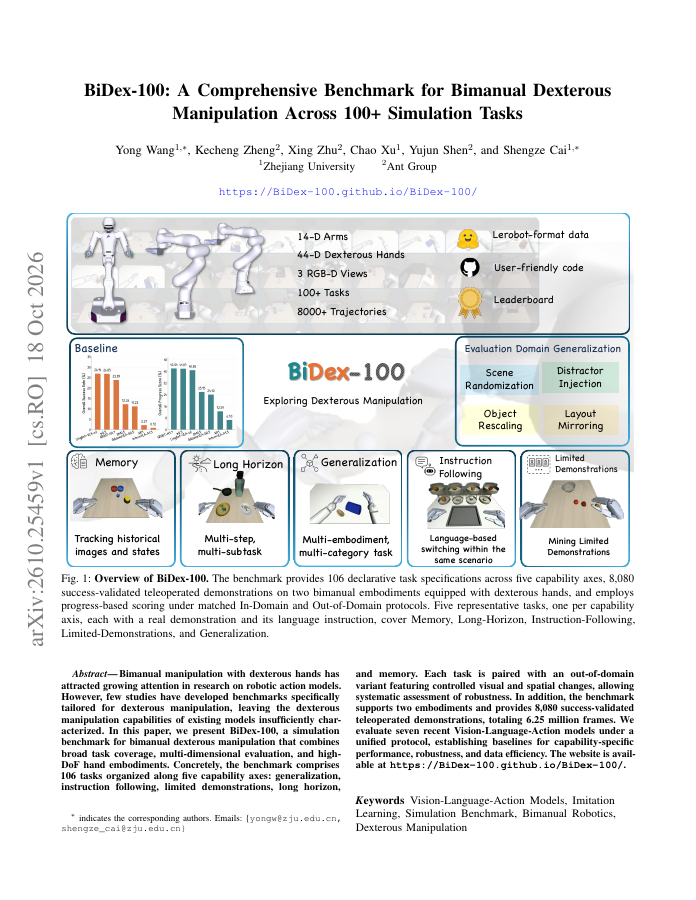
Bimanual manipulation with dexterous hands has attracted growing attention in research on robotic action models. However, few studies have developed benchmarks specifically tailored for dexterous manipulation, leaving the dexterous manipulation capabilities of existing models…
19 Oct 2026
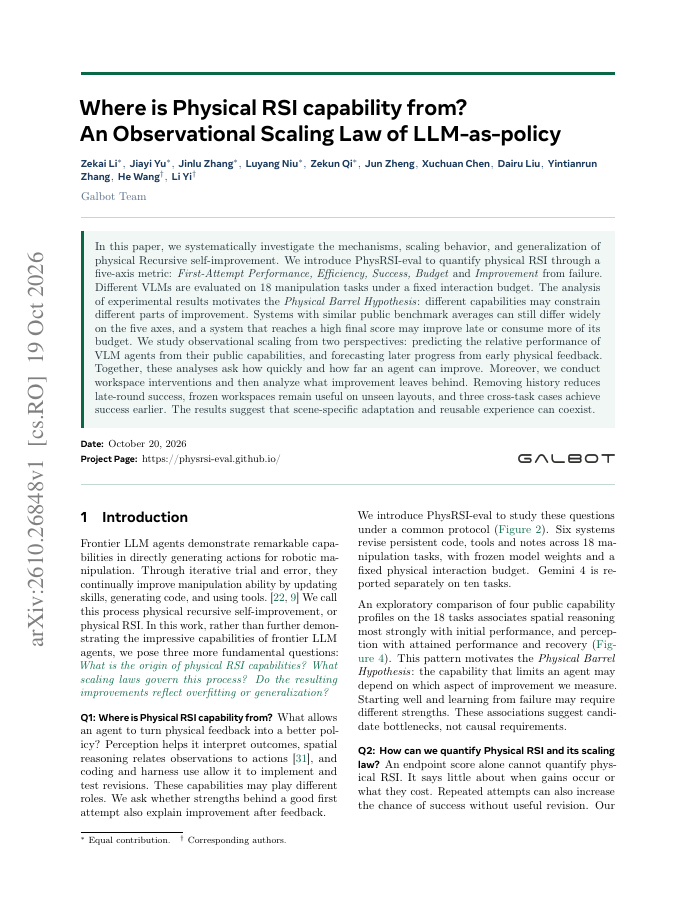
In this paper, we systematically investigate the mechanisms, scaling behavior, and generalization of physical Recursive self-improvement. We introduce PhysRSI-eval to quantify physical RSI through a five-axis metric: First-Attempt Performance, Efficiency, Success, Budget and…