19 Oct 2026
GPT-6-Astra demonstrates a level of competence in robotic manipulation and navigation that challenges the conventional paradigm of building specialized models for individual tasks and embodiments.
Trending research and the full catalog - each paper linked to the benchmarks, methods, and models it introduces.
Filtering here covers the 2,000 most recent papers, as much as one page can hold in memory. See the full index of 22,656 papers.
19 Oct 2026
GPT-6-Astra demonstrates a level of competence in robotic manipulation and navigation that challenges the conventional paradigm of building specialized models for individual tasks and embodiments.
18 Oct 2026
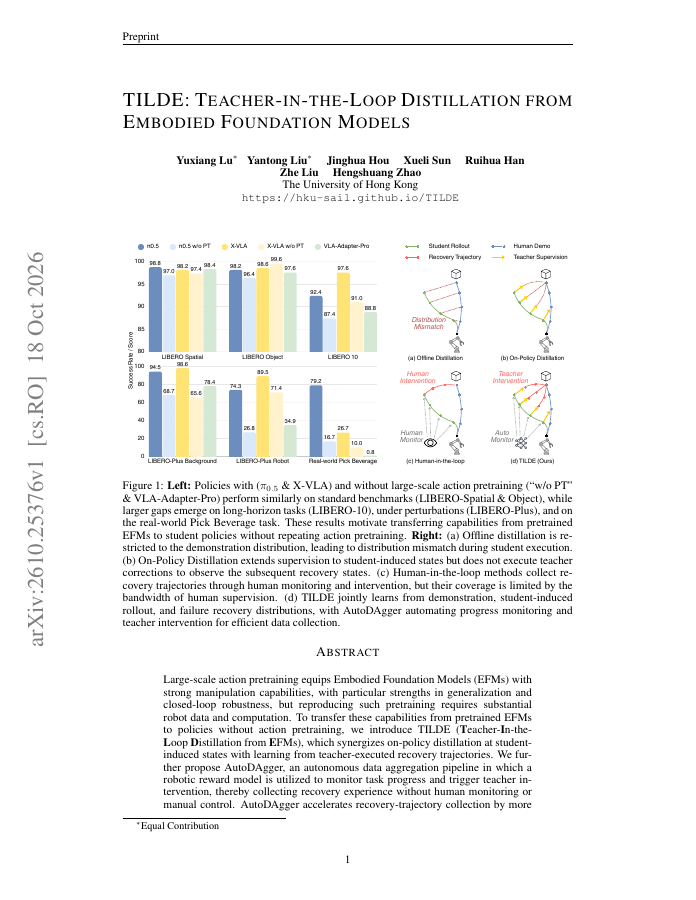
Large-scale action pretraining equips Embodied Foundation Models (EFMs) with strong manipulation capabilities, with particular strengths in generalization and closed-loop robustness, but reproducing such pretraining requires substantial robot data and computation.
18 Oct 2026
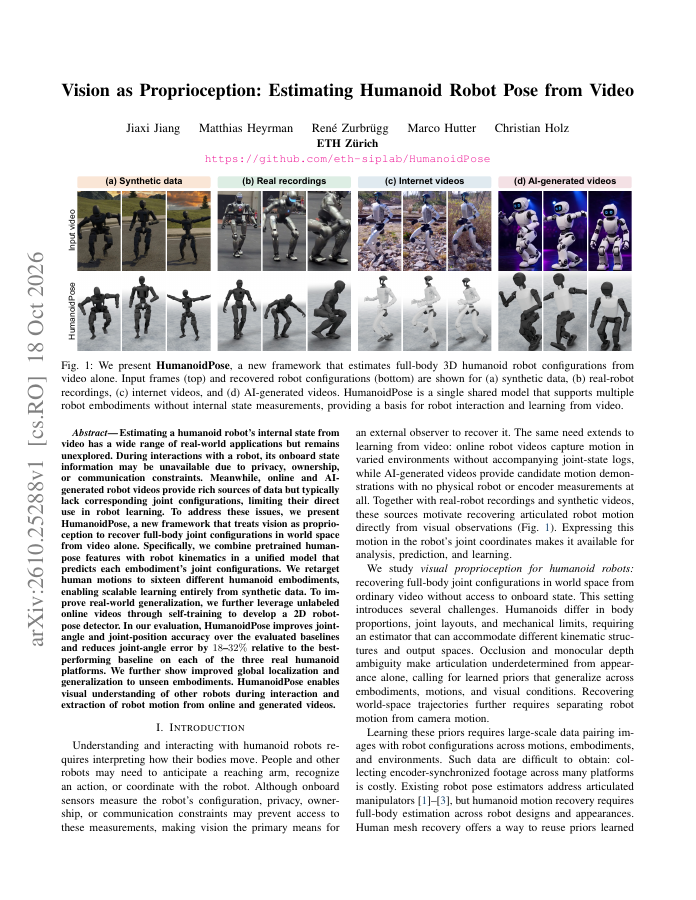
Estimating a humanoid robot's internal state from video has a wide range of real-world applications but remains unexplored. During interactions with a robot, its onboard state information may be unavailable due to privacy, ownership, or communication constraints.
18 Oct 2026
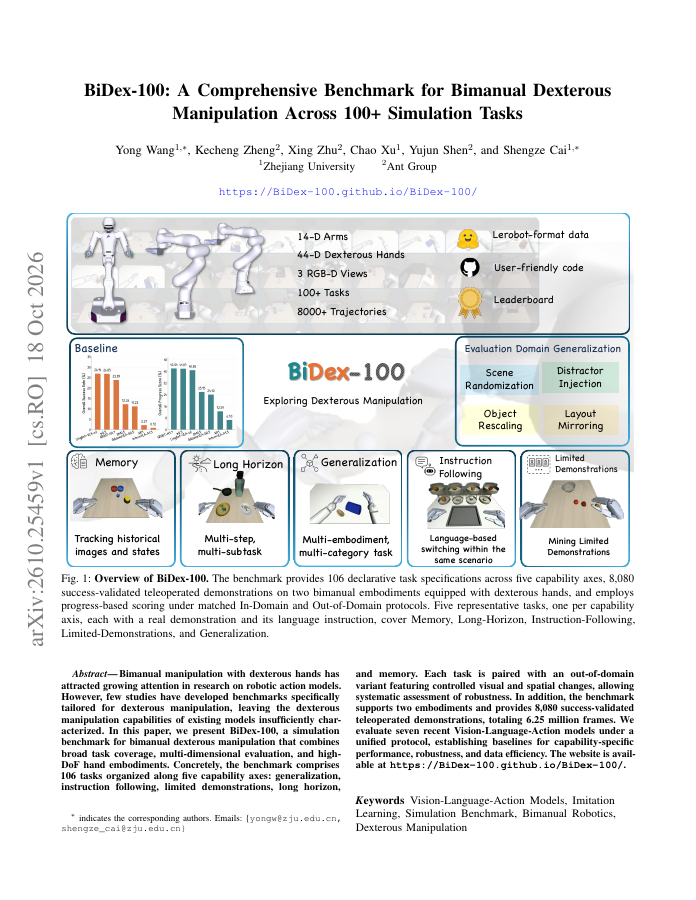
Bimanual manipulation with dexterous hands has attracted growing attention in research on robotic action models. However, few studies have developed benchmarks specifically tailored for dexterous manipulation, leaving the dexterous manipulation capabilities of existing models…
19 Oct 2026
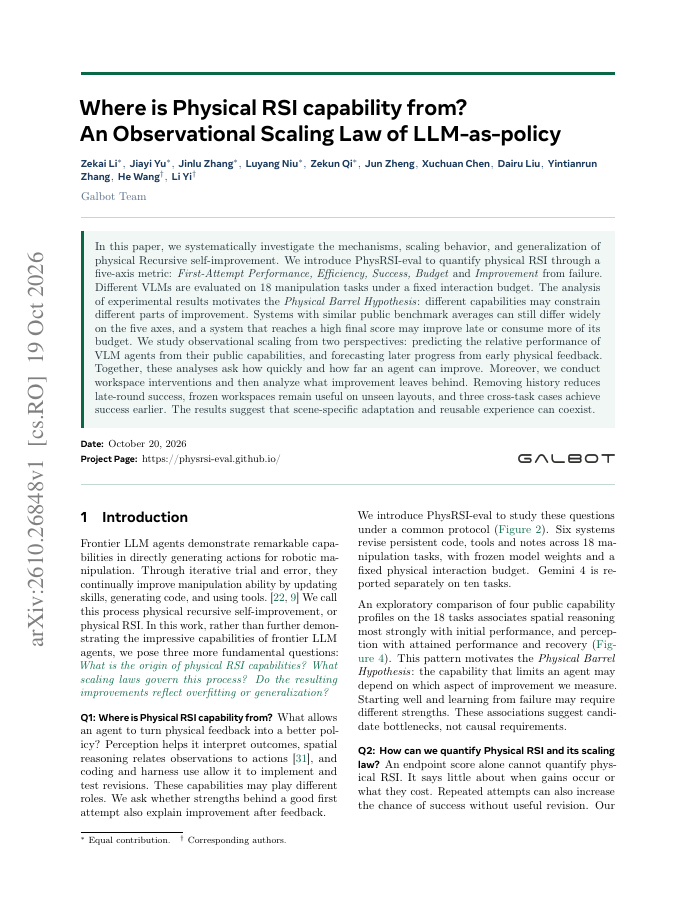
In this paper, we systematically investigate the mechanisms, scaling behavior, and generalization of physical Recursive self-improvement. We introduce PhysRSI-eval to quantify physical RSI through a five-axis metric: First-Attempt Performance, Efficiency, Success, Budget and…