Coding Agents for Generalized Task and Motion Planning Problems
24 Sep 2026
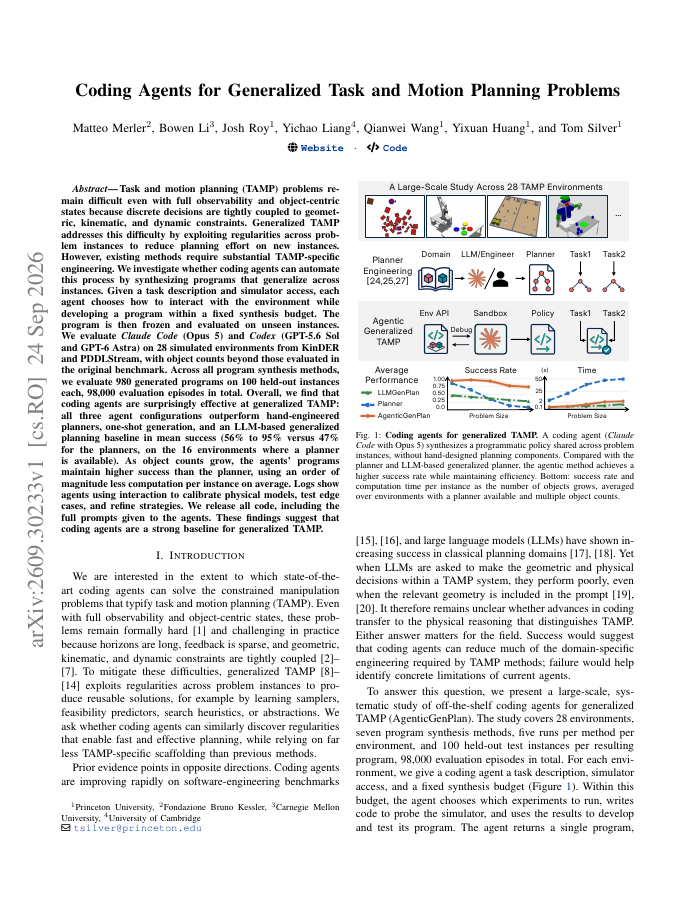
Task and motion planning (TAMP) problems remain difficult even with full observability and object-centric states because discrete decisions are tightly coupled to geometric, kinematic, and dynamic constraints.
240.1/h
