24 Sep 2026
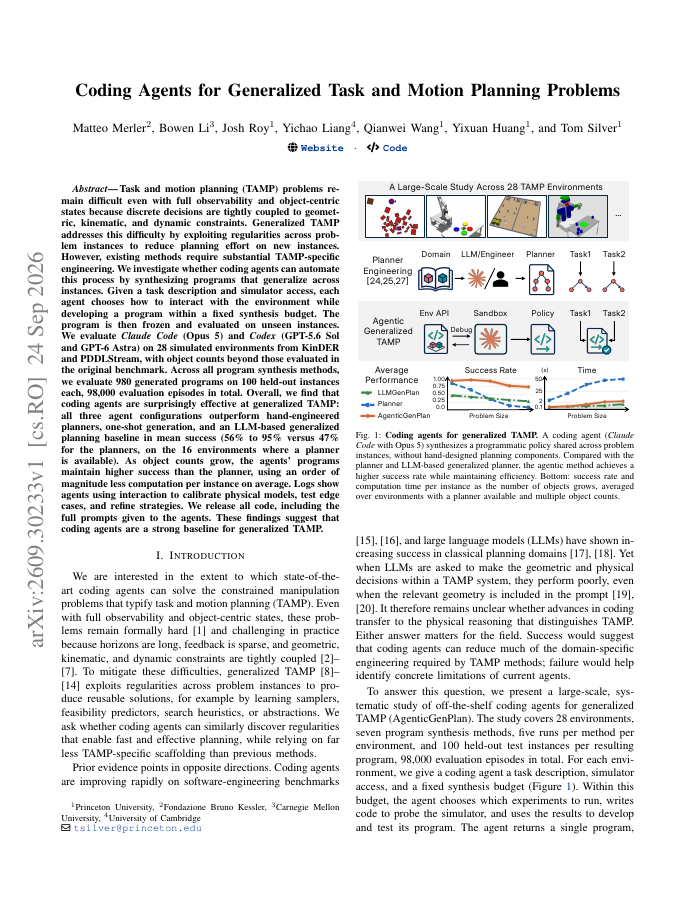
Task and motion planning (TAMP) problems remain difficult even with full observability and object-centric states because discrete decisions are tightly coupled to geometric, kinematic, and dynamic constraints.
Trending research and the full catalog - each paper linked to the benchmarks, methods, and models it introduces.
Filtering here covers the 2,000 most recent papers, as much as one page can hold in memory. See the full index of 22,347 papers.
24 Sep 2026
Task and motion planning (TAMP) problems remain difficult even with full observability and object-centric states because discrete decisions are tightly coupled to geometric, kinematic, and dynamic constraints.
9 Sep 2026
Foundation vision-language models (VLMs) exhibit broad intelligence about the world, yet translating this intelligence into robot control remains challenging. We present Show-Harness, an Embodied Harness that enables VLMs to "play" robots through a compact semantic…
Francesco Pasti, Jeremy Klotz, Nicola Bellotto et al. · 19 May 2026
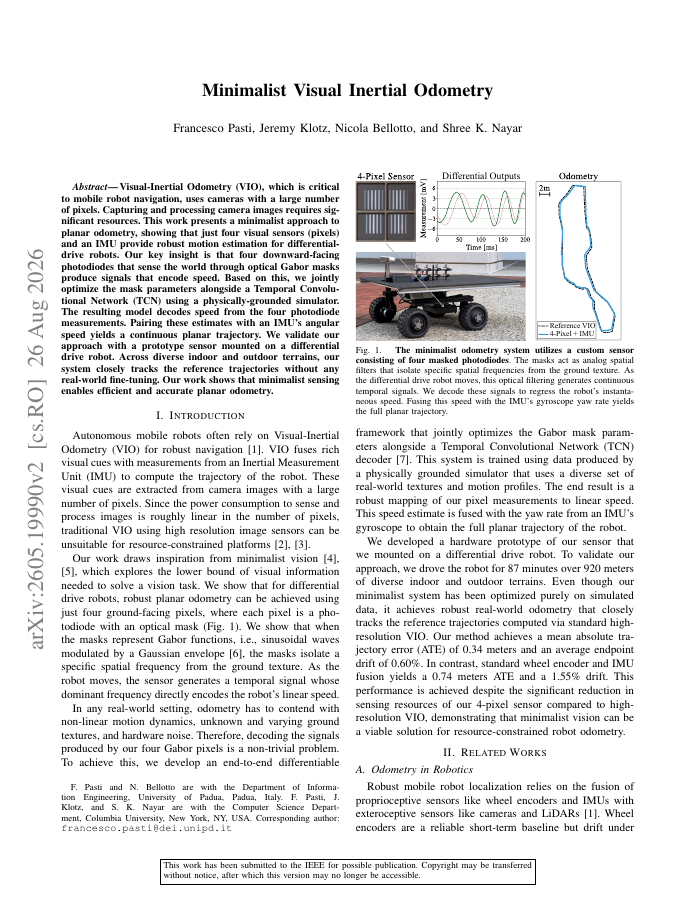
Visual-Inertial Odometry (VIO), which is critical to mobile robot navigation, uses cameras with a large number of pixels. Capturing and processing camera images requires significant resources.